Antennas
To optimize performance in a small form factor the Track Box Passive contains 2 antennas internally, TX (transmit) and RX (receive). The TX antenna is located in the lower half of the box and the RX is in the upper half, each antenna needs a clear line of sight to transponders in order to receive passings.
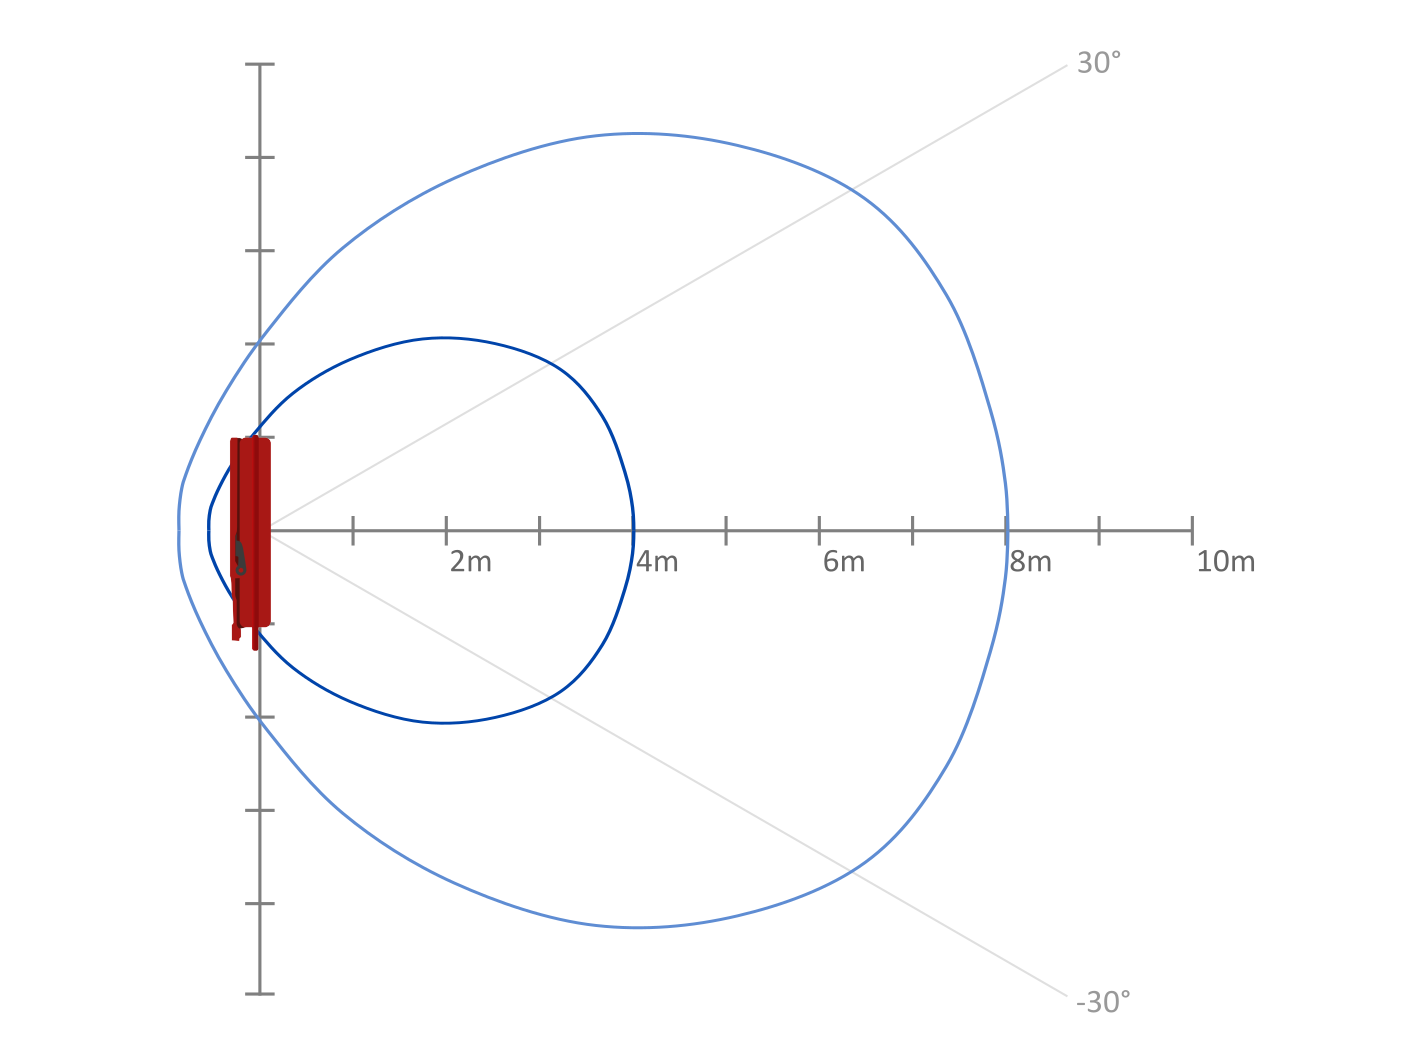
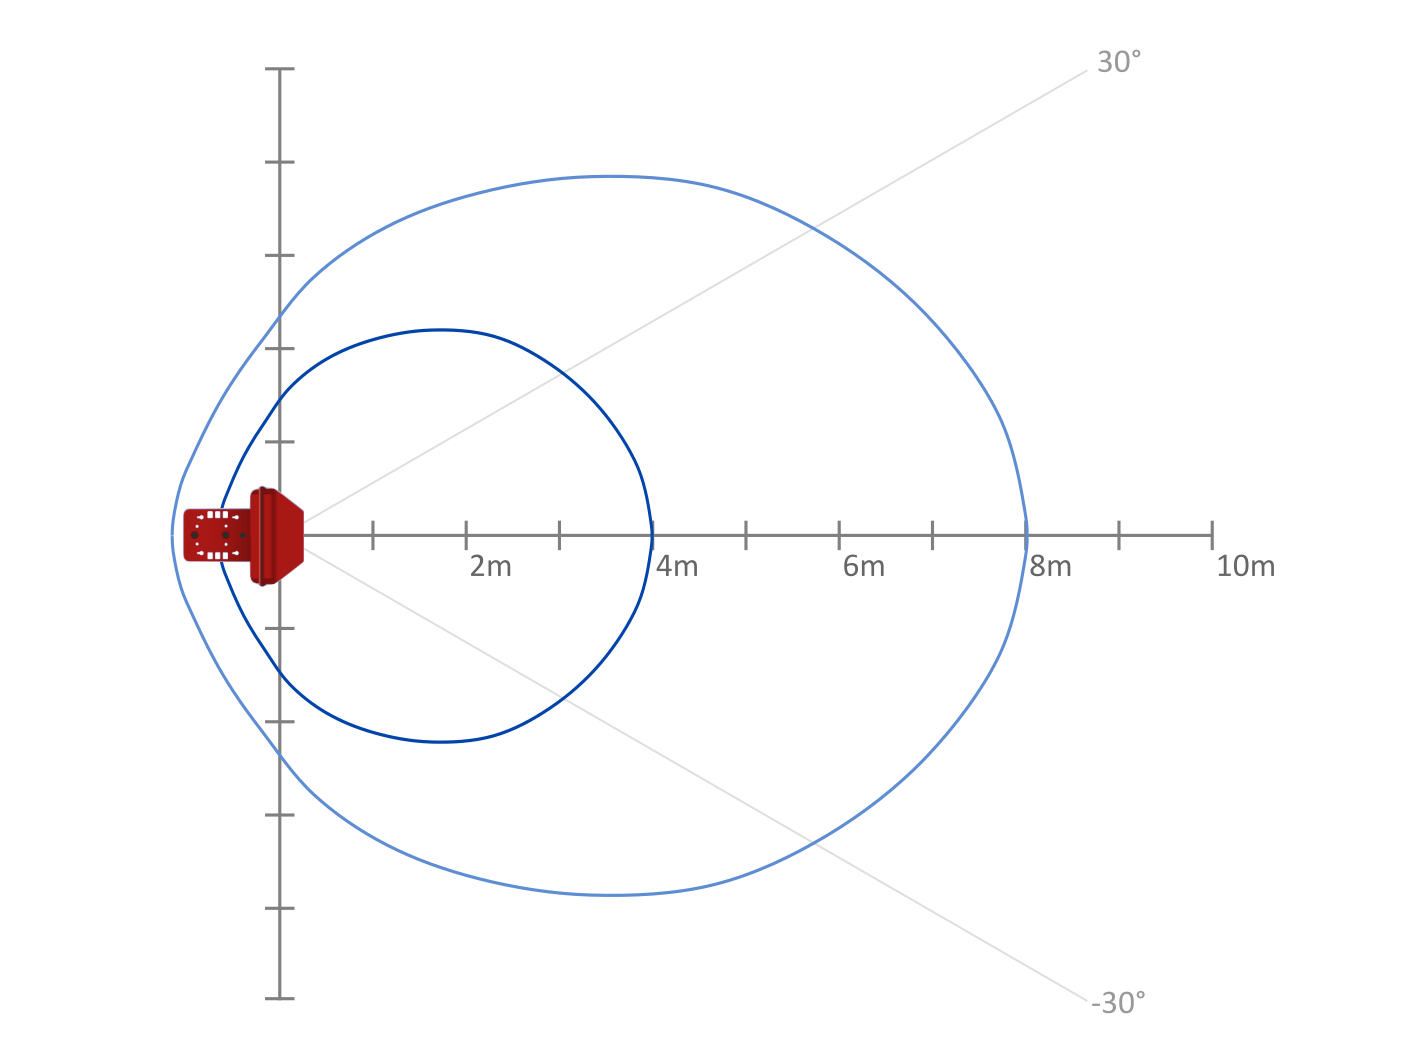
The below diagrams show the shape of the antenna field, the inner line represents expected 99% read rate at 4m from the front of the antenna, the outer line shows the 8m line with 90% expected read rate (with a single box).
Side View
Top View
Algorithms
Passive Transponders
Reaction Time & Dead Time
Similar to the RACE RESULT Decoder the Track Box (Passive) uses a detection algorithm to maximise the accuracy of recorded times.
The 2 key settings are the Reaction Time and Dead Time, which by default are set differently on Track Boxes due to their design.
The default Reaction Time is 10 seconds, the reason for this is that with antennas mounted to the side there is much greater chance of early detections, particularly if the Track Box is facing participants. A low reaction time may result in a less accurate time being recorded, by increasing this to 10 seconds it provides greater chance to record an accurate time. This does result in data being sent to the servers after a minimum of 10 seconds, so if speed of data is more critical than accuracy then this could be reduced.
Dead Time is set by default to 20 seconds, meaning that after a time is recorded then another passing will not be captured for 20 seconds, beware if using this on short laps or turnarounds. If multiple passings are expected within a shorter time then this can be reduced as necessary.
Both reaction time and dead time can be configured using Track Box Configuration Rules.
Hits & RSSI
When using the Track Box (Passive) you should also expect less hits compared to a RACE RESULT Decoder with standard antenna, this is due to the communication protocol used between Track Box and Transponder.
The reader will only communicate with each transponder in one of every 5 cycles, this maximises the opportunity for other transponders to communicate with the reader and thus maximising overall read rates.
Guidelines for RSSI values remain the same as Decoder detection data.
Passive Modes
The Mode set through Track Box Configuration Rules affects the read rate of the UHF antennas, data transmission and thus also has an impact on battery performance. The Track Box Passive supports normal, slow and standby mode. Fast mode is a Track Box Active mode; if it is set on a Track Box Passive the box runs in normal mode instead..
| Normal | Slow | Standby | |
|---|---|---|---|
| Recommended for | General timing | Slow-moving particpants and only a few transponders in the read field at the same time | Overnights, before or after the event, boxes that are set up buy not yet needed |
| UHF reader | On, 50 reads per second | On, 10 reads per second | Off, no transponders detected |
| Dual Track Box synchronisation | Available | Switsched off | Not applicable |
| Status call | Every 4 minutes, Every 15 seconds while traveling or has many passings waiting | Same as Normal | Every 15 Minutes |
| GPS | Switched off automatically while the box is not moving | Same as Normal | Switched on shortly before a status call if the box has moved since the last status |
| Battery use | Normal | Reduced | Lowest |
Normal
Normal mode is the best compromise for general timing and recommended for most applications. In this mode, the GPS module is shut down if the box does not move and the device status will be updated every 4 minutes, or every 15 seconds while the box is moving or still has passings to upload.
In normal mode the antennas are reading 50 times per second, and passings will be uploaded in small chunks with smart processing to minimise delay and data consumption accordingly. When two boxes run as a synchronized pair, the read rate of each is reduced — see Track Box Synchronization. If there is no data transmission pending then the modem will disconnect from the network.
Slow
Slow mode reduces the power consumption of the UHF reader while still detecting transponders. Use it where participants move slowly past the timing point and only a few transponders are in the read field at the same time — typical examples are checkpoints on trail runs, hikes or other slow-moving events.
In slow mode the antennas are reading 10 times per second instead of 50, and Track Box Synchronization is switched off. Note that this means slow mode should not be used where two boxes are set up as a synchronized pair. The status interval and GPS module behaviour remain the same as normal mode.
Active Track Pings received by the box are finalized 60 seconds after the strongest Track Ping instead of 10 seconds, or up to 120 seconds for a weak signal, so these pings reach the server considerably later than in Normal mode.
In slow mode, you can expect battery life of over 24 hours from a full charge.
Standby
In standby the UHF reader is switched off and transponders are not detected, and the box only sends a status call every 15 minutes. See Standby Mode. The box continues to receive Active Track Pings while in standby.
Other read rate reductions
Independently of the Mode, the read rate is reduced if the box runs on a solar panel that delivers little power and the battery is below 75%, where it drops to about 33 reads per second.
Automatic switch to Standby
In some situations the box switches to Standby on its own, regardless of the configured Mode, and returns to the configured Mode once the condition ends:
Auto Standby: During the time window set in the Auto Standby rule of the Track Box Configuration Rules
Low battery: When the battery is almost empty, to keep the box able to report its status and position for longer
Excessive current draw: If the box detects an abnormally high current draw
When does a mode change take effect
The box receives its configuration with each status call, so a new Mode takes effect with the next status call; within up to 4 minutes in Normal mode, or up to 15 minutes from Standby. The box sends a status call as soon as the Mode changes, so the new Mode is visible in RACE RESULT 14 right away. After a restart, the box starts in Normal mode and applies the configured Mode with its first status call.
Sincronización de las Track Box
Como ocurre con todos los sistemas de cronometraje UHF, un transpondedor sólo debe estar en el campo de un lector a la vez; además, la fuerte salida de un lector puede inhibir la antena receptora de otra Track Box cuando están directamente frente a frente.
Para evitar interferencias entre dispositivos, las Track Boxes pueden sincronizarse utilizando los 2,4 Ghz integrados, lo que evita la colisión de los lectores UHF. Hay 2 modos de sincronización: emparejamiento (2 Track Boxes) y múltiple (más de 2 Track Boxes).
Dos o más Track Boxes sincronizarán automáticamente sus lectores UHF para optimizar el rendimiento de lectura cuando:
- Las cajas están a poca distancia entre sí (aprox. 20 m).
- El mismo canal de 2,4 GHz está configurado.
- El lector está encendido (no en espera ni acostado)
- El lector está en modo NORMAL (no LENTO)
Cuando la sincronización esté activa, el LED verde (para indicar que el GPS y la red están bien) cambiará a un doble parpadeo rápido.
La sincronización de Track Boxes duales siempre se habilita automáticamente, independientemente de la orientación de las antenas, ya que incluso 2 Track Boxes que estén de espaldas entre sí pueden experimentar alguna interferencia.
La sincronización se desactiva automáticamente si los criterios anteriores ya no se cumplen, por ejemplo, si las Track Boxes se separan o se cambian los canales de las mismas. También es posible desactivar la sincronización de Las Track Box dual usando Custom Track Box Configuration Rules.
Como la sincronización de Track Box y el Active Track Ping Detection dependen de la antena de 2,4 GHz, no se recomienda utilizar la sincronización de Track Box mientras se esperan Active Track Pings, ya que esto reducirá la posibilidad de que Track Boxs reciban Active Track Pings. Además, los Track Boxes solo pueden funcionar en un solo canal, por lo que cambiar el canal para emparejar dispositivos cambiará el canal en el que el dispositivo espera recibir Track Pings.
Emparejamiento de las Track Box
El uso de dos Track Boxes juntos permite cubrir un mayor ancho de punto de sincronización y también maximiza la posibilidad de una línea de visión clara entre las antenas y los transpondedores. Cuando estén en modo de emparejamiento, las Track Box informarán SYNC en la pestaña RACE RESULT 12 Timing.
Cuando esté en modo de emparejamiento, la velocidad de lectura de cada Track Box se reducirá a poco más de la mitad, a alrededor de 20 veces por segundo (frente a aproximadamente 50 veces por segundo para un solo Traxk Box no emparejado), lo que resultará en una reducción de visitas por Track Box, para cada transpondedor. Al comparar el rendimiento de un par de Track Box con el de un solo cuadro, se pueden esperar resultados más o menos similares; sin embargo, es probable que la suma del par sea ligeramente menor debido a que tiene poco menos de la mitad del tiempo de lectura disponible por Track Box.
Si tiene varias Track Boxes a corta distancia, puede crear pares de dispositivos configurando el canal correspondiente para cada dispositivo. En este caso, debe tener cuidado de que 2 dispositivos cualesquiera que no estén sincronizados no tengan campos superpuestos que puedan causar interferencias.
Multi Track Box
Cuando hay más de 2 Track Boxes a corta distancia y cumplen con los criterios de sincronización, ingresarán al modo múltiple; esto también se indica en la pestaña Cronometraje RACE RESULT 12.
En el modo múltiple, cada Track Box reducirá drásticamente su velocidad de lectura a un modo aleatorio mucho más lento. Este modo está diseñado para usarse en aplicaciones en interiores con muchas Track Boxes muy cerca y no está diseñado para cronometraje deportivo.